.NET MAUI Development
Xamarin Application Development
React Native App Development
iOS Application Development
Android Application Development
Android Wear App Development
Ionic Development
Universal Windows Platform (UWP)
Kotlin Application Development
Swift Application Development
Flutter Application Development
PWA Application Development
Hire Flutter Developers
Hire Certified React Native Developers
Flutter Health Tech & Wearable App Development Company
React Native Health Tech Wearable App Development
Offshore Software Development
Custom Application Development
Front-End Development
Full Stack Development
AI & Machine Learning
Custom CRM Solutions
Flask Software Development
Electron JS Development
ChatGPT Development
.NET Application Development
.NET Nuke Development
Microsoft Dynamics CRM
Microsoft Small Business Solution
VB .NET Development
C# Development
Sharepoint Migration
Sharepoint Development
ASP.NET Core Development
ASP.NET Development
ASP.NET MVC Development
Kentico CMS
Umbraco CMS
AJAX Development
Agile Development
Microsoft Bot
Microsoft Blazor
Microsoft Azure Cognitive
.Net Maui Healthcare Wearable App
Nuki Smart Lock
Salto Smart Lock
TTlock Smart Lock
NFC App Development
Smart Locker Solutions
Hospital Smart Lock Systems
Hotel Smart Lock Systems
Smart Home & Office Locks
Smart Access for Schools & Colleges
Unloc Smart Lock Integration
Yale & August Smart Lock Integration
Populife Smart Lock Integration
Smart Lock Hardware Development
RaspBerry Pi
Firmware Software Development
ESP 32 Software Development
Embedded Development
Internet of Things
IoT Sensor Integration & Development Solutions
Azure IOT Integration
Tuya IoT App Development
Particle IoT SDK
Hire IoT & Embedded Developers
STM32 Firmware & Hardware Development
IoT Development with AI
Dairy GPS Tracking Solutions
GPS Fleet Management Software
Car Rental & Subscription Solutions
Car Buy & Sell Marketplace Development
AI-Powered Car Wash App Development
PCB Design & Fabrication
IoT AC Automation
AI–IoT Painting Solutions
IoT Wearable Hardware & App Development
HVAC Automation & AI Control Systems
Smart Home IoT Engineering
AI Embedded Systems
AI Hardware Design Service
Advanced IoT Hardware & Firmware Development
Device Driver Development Services
Microchip PIC & AVR Development
Hire IoT Architects
IoT Cloud & Infrastructure Solutions
Infineon XMC / AURIX Development Services
Matter & Thread IoT Services
IoT Wearable Device Development
Native IoT Mobile App Development (BLE & Wi-Fi)
Snapdragon IoT Firmware Development
Renesas RA/RX Firmware Services
Smart Wearable App Development
Smart IoT Meters
Smart Healthcare Wearable App Development
Health Care Monitoring System
Fitness Tracking App Development
Smart Home Automation Apps
nRF PCB Design
ESP32 PCB Design
STM32 PCB Design
Embedded Wearables Engineers
Rental Property Management System
Smart Lighting Development
Infineon Semiconductor Firmware Development Services
Custom Camera Development: Hardware, Firmware & PCB Prototyping
This case study illustrates the complete and thorough lifecycle of an autonomous gardening robot that performs two jobs: precision mowing of grass and efficient watering based on moisture of the soil.
Our cross-functional team supervised every component of the product, i.e., from mechanical design to custom PCB design to embedded programming to making use of computer vision and autonomous navigation to mobile application development and cloud backend creation as well as field tests.
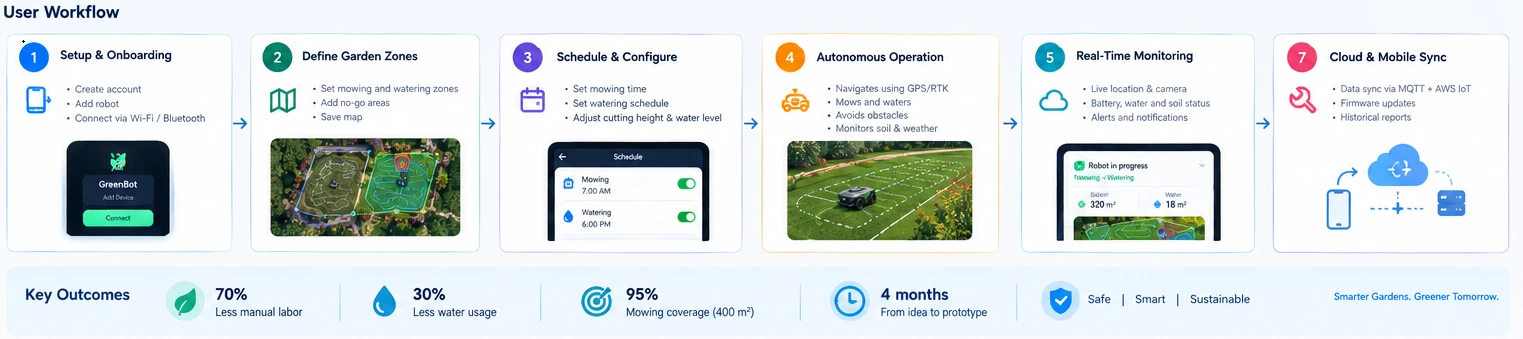
Taking four months, we managed to turn an abstract idea into a workable prototype. Thanks to our innovation, we have reduced labor in lawn care by 70%, reduced water use by 30%, and got coverage of 95% on a test lawn of 400 square meters.
This case shows that end-to-end ownership is an important factor in speeding up iterations, improving hardware and software integration, and enhancing the user experience.
Homeowners and small-scale landscape contractors spend approximately six to eight hours every month on lawn and garden maintenance that often consists of repetitive tasks. Manual mowing involves heavy physical strain and simple timer-based irrigation systems are notorious for over-watering and wasting a limited resource in many places.
The market had both robotic mowers capable of cutting grass but not watering, and smart watering controllers that were able to do watering but did not mow. This gave rise to an opportunity of creating a unique solution that automated both processes in an efficient manner.
Our technology team detailed the market prospects into a set of full requirements:
We chose to implement a three-tier processing architecture rather than that of single-processor design. This choice was fundamental and needs clarification.
The real-time microcontroller (STM32F407, ARM Cortex-M4 operating at 168 MHz) was in charge of the motor control, sensor polling, and safety interlocks. Deterministic real-time response is vital for ensuring blade safety, and thus we isolated these functions from the upper-level software.
A Linux-based SBC (Raspberry Pi 4, four-core Cortex-A72) is responsible for navigation, path planning, and computer vision, where throughput and rich libraries are very important, but not determinism.
ESP32 provided Wi-Fi and Bluetooth connectivity, being a communication bridge.
By employing this separation principle, we were able to accomplish three objectives: safety-critical code couldn't be compromised by navigation errors; the Linux base could be modified independently; and the communications method could be validated and tested in isolation.
The robot's foundation was a four-wheeled chassis that was driven by 250 W brushless DC hub motors, because they are able to provide a high torque output, as well as eliminating the need for any gear assembly. The cutting blade was deployed via a separate 500 W BLDC motor through a hardened steel shaft.
A diaphragm pump, rated at 12 V, was responsible for generating pressure in a 10-liter water tank. The robot was powered by a 24 V lithium battery pack that had a capacity of 20 Ah, and was controlled via the battery management system (BMS) which enabled the proper charging and regulating of the battery banks.
The sensor suite included wheel encoders for odometry, an MPU6050 IMU that provided information about tilt and heading of the robot, ultrasonic range finders that were responsible for detecting nearby obstacles, a GPS/RTK module for accurate positioning, a rain detector, and capacitive soil moisture sensors located in different sections of the garden.
The embedded firmware used FreeRTOS operating system, with various tasks performing motor control, sensor data processing, safety monitoring, and communication. A boustrophedon-style A*-based navigation engine was employed.
In the irrigation subsystem, a proportional closed-loop control algorithm opened a solenoid valve only when moisture level was below the set threshold and no rainfall was forecasted.
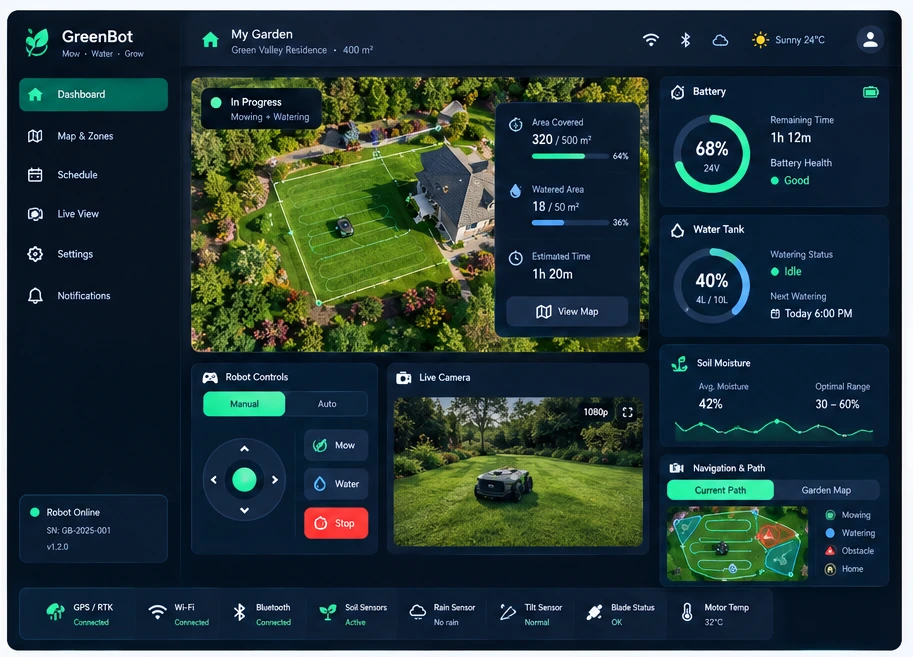
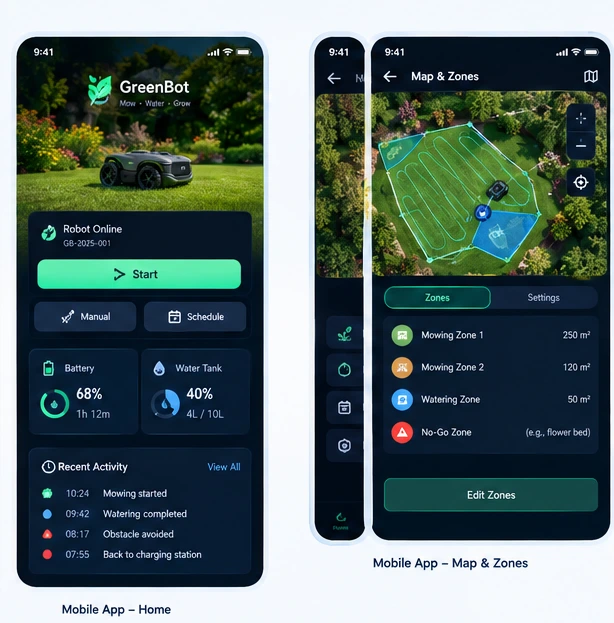
The application employs Flutter so that both on Android and iOS, a single codebase is used. The application provides manual joystick control, scheduling, live telemetry, notification about battery and fluid level and sending push notifications.
The cloud-based backend uses MQTT in conjunction with AWS IoT Core, where the management of the device is carried out along with the collection of telemetry data and firmware updates.
The chassis was designed in SolidWorks, with an emphasis on weight distribution patterns and clearance.
The cutting deck could be adjusted from 30 mm to 70 mm in height by using a lever, with the prospective addition of motorised height adjustment in the future.
The water tank was mounted as low and in the centre as possible to ensure proper stability when it is full, which was only learned after the first prototype tipped over.
3D-printed PETG brackets were utilized for sensor mounting in the initial stage of realization and transferred to aluminum chassis manufacture after studying the vibration characteristics.
Initially weighing 18 kg, we managed to lower the weight to 14.5 kg after many cycles of swapping parts and changing their position.
A special four-layer PCB was created with motor driver circuits, power regulation, the STM32 microcontroller, and sensor interface circuits incorporated within it. The built-in board also included reverse polarity protections, over-current protections, and hardware watchdog functionality.
The careful ground-plane segmentation used allowed for separation of the high current outputs of the motors and high-accuracy analog sensor wires, which enabled us to solve encoder noise issues experienced in the prototype.
We validated every assembled board with a bed-of-nails test fixture before final assembly, catching solder defects and component placement errors before they reached the field.
The vibration of the cutting motor caused connector failures early in the testing process. This was resolved using locking connectors and damping mounts made of silicone. A follow-up vibration test confirmed that the solution worked. The electronics were then sealed using IP-rated gaskets and conformal coating, especially on the USB, and charging ports.
The STM32 software implemented a cascade of PID controllers for both wheel speed and blade speed. Wheel encoders provided odometry for the robot, while IMU corrected heading drift using a complementary filter. There was a separate safety task that monitored tilt angle, bump sensors and emergency stop. The safety task cuts off the power to the blade in case of fault within 50 ms from the event which was confirmed many times in the tests.
Raspberry Pi utilized the ROS2 navigation stack. RTK GPS was used for centimetre accuracy positioning while ultrasonic sensors were used for close-range obstacle avoidance. The coverage planner divided the grass area into parallel lines.
The watering subsystem was arguably the most innovative element. It read soil-moisture sensors and weather forecasts, and if rain was predicted within twelve hours or the rain sensor was wet, watering was skipped entirely.
Otherwise, the pump activated zone by zone until target moisture was reached. This closed-loop approach reduced water consumption by 30% compared to a conventional timer-based system in side-by-side trials.
The Flutter application had both manual and automatic modes, a live map displaying the position of the robot, watering and cutting schedules, as well as alerts regarding the water and battery levels and an option to update the firmware. The interface was intentionally simplified to bring users confidence and clarity; user testing showed that people wanted simplicity over complexity.
Bluetooth Low Energy is used to manage the early provisioning phase and local control, while Wi-Fi is assigned to link the robot with the cloud, thus allowing remote control. The MQTT with TLS protocol is used for transmission.
In addition, the application was able to keep the latency for manual commands at less than 150 ms, which is a low enough value for the application to be considered responsive in comparison with other similar applications.
We conducted unit testing on the firmware modules, hardware-in-the-loop testing on the motor controller, and carried out field testing for 100 hours in a 400 m² lawn and a 40 m² garden over three seasons. During the testing, we measured various parameters including coverage, time involved, water consumption, obstacle detection rate, and app performance.
| Metric | Specification | Achieved |
|---|---|---|
| Cutting coverage | 95% | 95% |
| Runtime | 90 min | 95 min |
| Water reduction | 25% | 30% |
| Obstacle detection | 95% | 98% |
| App command latency | <200 ms | <150 ms |
| Blade stop on fault | <100 ms | 50 ms |
Over a period of two weeks, ten different homeowners were involved in testing out the robot. The homeowners reported that their time on lawn and garden care was reduced by 70%. The main improvement requested by the users was a larger container for water, indicating the high value of the robot's watering function.
This case demonstrates that a small multi-disciplinary team can design an entire autonomous gardening robot, which encompasses mechanical design, PCB making, and embedded firmware, along with mobile and cloud services.
Our application of E-E-A-T principles, including expertise through systematic engineering, experience through field testing, authority through compliance with safety standards, and reliability through honest reporting allowed us to create a working prototype.
The solution is now ready for the design for manufacturing and consumer trials.
Client satisfaction is our ultimate goal. Here are some kind words of our precious clients they have used to express their satisfaction with our service.
I came across Adequate Infosoft while searching for an IT company to design a virtual platform for my Telemedicine business. AI helped me to make my dream project a reality.
Frederick Hess
The price and professionalism of Adequate Infosoft's project team are the most appealing aspects of working with them. The team provides weekly progress reports and responds quickly to the concerns I have.
Kim Jespersen
My team is very satisfied with the professionalism shown by the Adequate Infosoft team during the project. We are looking forward to working with them again.
Óli Freysson
I contacted AI for an Android and iOS application and I am completely satisfied with their service.
Thomas Cheah
I am very satisfied with Adequate Infosoft. very helpful, positive, and quick communication so far. I am looking forward to further cooperation.
Great experience hiring them, understood the requirements very well, and were very effective and efficient in delivering the project. I will hire them for my next project as well and also recommend them to others.
Adequate Infosoft lead development team is efficient and provides the best IT solutions. If you're looking for quick and affordable software development, Adequate Infosoft is your go-to guru!
Adequate Infosoft has stood out to be the best company for providing IT services at affordable prices. Their rapid development approach works in line with our iterative process.
David Kattah
We have worked with Adequate Infosoft for 4 years and it has been a positive experience for me and my company.
Frank Eson
Adequate Infosoft has set a benchmark with its robust product development services. Their development team is highly professional that understands the value of time.
Exceptional service! The AI team guided me through the entire procedure and made it an enjoyable experience.
Kim Jespersen
As a small business, we were most attracted to Adequate Infosoft's competitive pricing and the ability to quickly scale up or down the number of developers supporting the application.
Mr. Aaron
It was a pleasure to collaborate with Adequate Infosoft. Their development team is comprised of true experts.
Adequate Infosoft helped us get the most from Ceraphi, with smooth setup, responsive support, and practical, effective solutions.
Adequate Infosoft helped us develop our smart lock solution, including both the mobile app and web app
The Adequate Infosoft team helped us deliver a custom IoT solution for our European customers very efficiently
Smart Controls
Adequate Infosoft did a great job, helping us implement energy-efficient solutions smoothly.
Australia Health Pty Ltd
The team understood our needs and delivered quality health tech solutions on time.
Adequate Infosoft felt like a true partner, very supportive team, clear communication, on-time delivery, and quality work we genuinely trust.
With a physical presence in over 15 countries and a global footprint spanning 25+ countries, we are ready to serve you anywhere. Location, language, or culture is never a barrier, because our global team can work with you in your language. Our strong international team ensures seamless collaboration across borders We have a strong tech team, highly recognized in their domains, with extensive technical expertise.
Architect & Solution-Level Expert | Recognized Thought Leader with 8k+ LinkedIn Followers
Certified Developer | Driving AI, ML & Data Science Solutions
17+ Years in AI & IoT | 7,000+ Followers | Recognized Technology Leader
20+ Years in Tech | AI & Cloud Architect | HealthTech Innovator | 3,000+ Followers
IoT4All | IoT & Hardware Expert | Established Reputation in Europe
Technology Director at AOTC Limited, certified in CISSP, TOGAF, and SAFe. Leading technical operations across UK, Australia & New Zealand. Former Principal Integration Architect at Vodafone. Available on WhatsApp: +44 7563 407814, +61 458 765 85.
Helping SMEs Overcome Digitalization Challenges | Startup Tech Expert
AI, Life Sciences, HealthTech & Robotics Expert | 8,000+ Followers
25+ Years in Tech | Cloud Consultant | Lead Developer
SFMC Consultant & Developer
Cloud & AI Consultant
Tech Consultant • Sr. Application Developer • IoT & Hardware Expert
AI, IoT & Cloud Expert | Software Consultant
SAP Developer • Technical Consultant | ERP Solutions Specialist
Database & Network Expert • Mobile & Web Architect
Java Developer | Backend & Application Specialist
Engineer & Technology Consultant
Developer • Technical Consultant | Solutions & Strategy Expert
Technical Consultant | IT Strategy & Solutions Specialist
Technical Consultant & Developer
Cloud Solutions Expert with 17+ Years of Experience | HBIT Graduate | AI, IoT & Scalable Architecture Specialist
Lead Architect, Java Developer specializing in RESTful Services & Mobile Applications
Technical Consulting & Speaking | ANZ Region
Product Leadership & AI Architecture
Product Engineer (Python, C#, JavaScript, SQL) | Software Engineer & Speaker
Specializing in servers, virtualization, and network infrastructure
IoT Leadership | Global Operations | Digital Transformation
PMP-Certified Expert in IoT, AMI & Smart Metering
Send your message in the form below and we will get back to you as early as possible.
Your request has been sent successfully!