Case Study: STM32-Based Custom Drone Platform Prototype Development STM32-based custom drone platform prototype development. Open-source quadcopter with custom PCBs, cascaded PID flight control, FreeRTOS firmware, 3D-printable airframe, and modular architecture for UAV research and education.

STM32-Based Custom Drone Platform Prototype Development

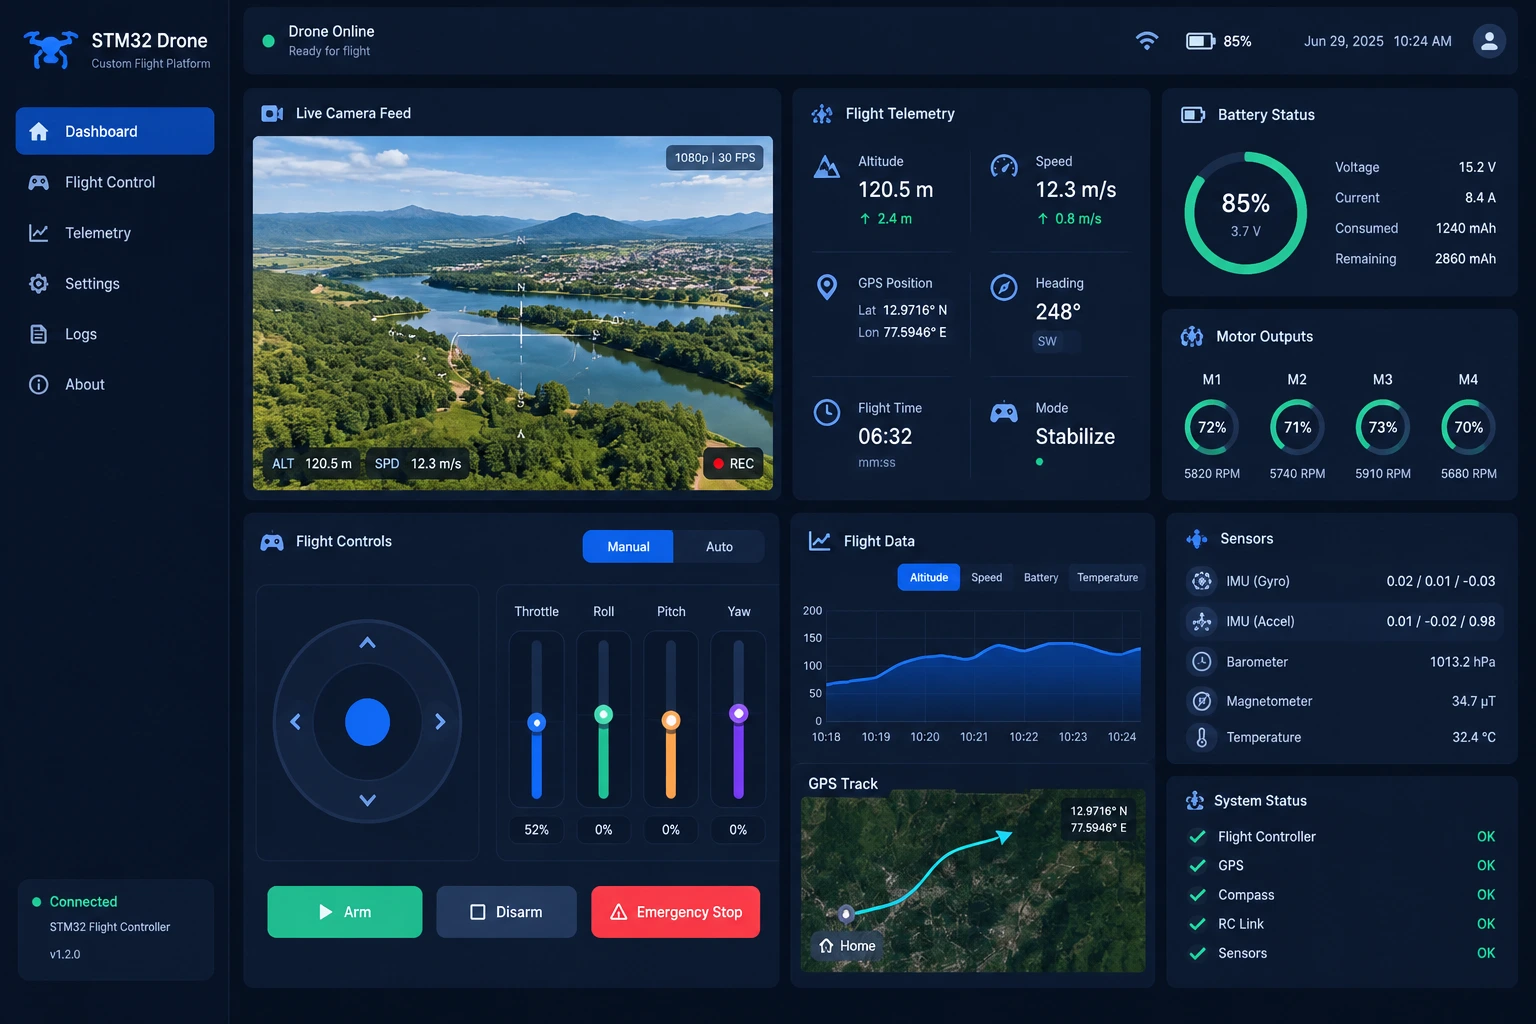
The STM32 Custom Drone Platform is an open-source quadcopter project that has been developed by IoT App Development Company. This project signifies a great improvement over the previous projects based on the ESP32 as it uses much more powerful STM32 microcontrollers.

Introduction

The STM32 Custom Drone Platform is an open-source quadcopter project that has been developed by IoT App Development Company. This project signifies a great improvement over the previous projects based on the ESP32 as it uses much more powerful STM32 microcontrollers.

The project was developed to overcome challenges which were faced with ESP32, particularly the issues with real-time performance, floating-point calculations and availability of peripherals.

The STM32 family of ARM Cortex-M microcontrollers offers superior clock speeds, dedicated floating-point units, and richer peripheral sets, making them ideal for advanced flight control applications.

The project delivers a complete UAV ecosystem encompassing custom mechanical design, multiple custom-designed PCBs, embedded C++ flight firmware, and 3D-printable airframe components, all documented and released under open-source principles.

Its design incorporates three key elements: the mechanics, the electronics, and embedded software. The framework promotes modularization enabling the separate upgrading or replacing of components as the system grows.

The resource ensures that all components are thoroughly documented so that engineers can replicate hardware, change firmware, and use the blueprints for learning about embedded systems or PCB design.

STM32-Based Custom Drone Platform Prototype

Mechanical Design and Airframe Development

STM32-Based Custom Drone Platform Prototype

Design Methodology

The airframe development relied on Autodesk Fusion 360, which is a sophisticated CAD software for accurate parametric modeling and iterative refinement of designs.

In the design methodology, three main goals have been taken into consideration: strength, lightweight, and easy assembly of the structure.

The prototype parts were produced via a Prusa MK3 FDM 3D printing machine chosen for its reliability, excellent printing quality, and popularness among makers.

Airframe Features

The mechanical design of the air frame has many unique features that make it different from ordinary drone bodies.

Lightweight frame design:

The frame has been designed in such a way that it minimizes the use of materials without compromising durability.

Modular construction:

Parts of the air frame are designed in such a way that they can be changed easily.

Easy-to-print components:

All parts of the frame have been designed for FDM printing, and the structures needed for making the parts have been minimized.

Serviceable design:

Parts of the air frame are accessible without taking apart the whole structure.

Optimized placement of parts:

Placement of the flight controller, power board, battery, and motors was done with keeping in mind that proper weight distribution and positioning avoiding resonance.

Expandable mounting system:

The frame has standardized mounting positions that allow adding monitors, GPS, and other devices without changing the structure. The CAD files are completely customizable and can be adjusted for different motors, batteries, sensors, etc.

Electronics and PCB Architecture

Overview of Custom PCBs

The electronic subsystem consists of various custom-designed printed circuit boards, which were created using KiCad, the open-source electronic design automation (EDA) software known for its professional-level schematic drawing features and PCB layout.

The choice of KiCad instead of proprietary software was made consciously so that the hardware designs can be shared with the open-source community without incurring any licensing charges.

PCB of Flight Controller

The Flight Controller serves as the central processing unit of the drone, interfacing with sensors, communication peripherals, and motor outputs. Its responsibilities include sensor acquisition, flight stabilization, PWM generation, telemetry, and safety monitoring.

The STM32 microcontroller used for this PCB serves the function of providing power for all the control systems of the drones. The introduction of effective algorithms like cascade loop PID in addition to sensor fusion processes is one of the major highlight of this PCB.

The design of the PCB incorporates a number of filtering capacitors, such as ground planes and filtered power supplies, to help in the work of a PCB through the low electronic variability of the drone.

Power Distribution Board (PDB)

This board represents a fundamental feature in the operation of the battery charges because it will ensure that battery power is being supplied to all electronic devices present on the board while also providing a secured supply of electricity to low-voltage systems. The board possesses the following characteristics:

Battery input

It receives the usual LiPo battery connectors and is also furnished with copper traces that can withstand extreme currents generated by motors.

Voltage regulation

Onboard voltage regulators ensure the output of stable voltages of 5 V and 3.3 V, which are vital for the sensor system and other devices.

Noise filtering

This function is handled with the help of LC filters and bulk capacitors which absorb transients caused by the operation of the engines.

Protection circuitry

The circuit includes fuses and TVS diodes that help prevent electrostatic discharges.

Expansion headers

The board's design allows adding extra ports and connectors to support additional peripheral devices while maintaining manufacturing.

Lighting Module

A specialized lighting PC board is responsible for visual status indication by means of several light-emitting diode (LED) components.

The lighting circuitry carries out communication about the power status, operation of the system, status of the flight, number of errors, and location of the light components at the same time ensuring that both operation and safety functions are satisfied.

The lighting module firmware is integrated with the main flight control unit, which makes it possible to ensure unity of the status reporting for all subsystems.

Embedded Software and Flight Control

Development Environment

The flight firmware is written in C++ and built using PlatformIO, a cross-platform development environment that provides unified toolchains, library management, and debugging support for embedded targets. PlatformIO's integration with Visual Studio Code offers a professional development experience with IntelliSense, serial monitoring, and firmware upload capabilities.

The choice of C++ over C enables object-oriented design patterns, improving code organization and reusability.

Software Architecture

The firmware is designed to be modular and utilizes custom libraries for easy upgrades and maintenance of the system. The architecture consists of:

  • Flight stabilization: This includes PID control loops to regulate the roll, pitch, and yaw values for ensuring stable flight while continuously correcting errors.
  • Sensor fusion: This refers to obtaining the values of the drone's attitude by combining accelerometer and gyroscope data using filter algorithms.
  • IMU processing: This deals with the acquisition of raw sensor data, its processing, and converting it into physical values.
  • Motor control: This produces PWM signals needed for electronic speed controllers and contains the process of which enables arm sequences and assigns throttle values.
  • Battery monitoring: It helps monitor voltage and current usage and sends alerts when the battery is low.
  • Failsafe handling: It is responsible for identifying loss of radio signal and/or sensors failure, activating necessary failsafe measures.
  • Communication interfaces: It is in charge of processing all incoming signals from the receiver and sending telemetry data, possibly using various communication protocols.
  • Hardware abstraction layer: Isolating hardware-specific codes from the application logic makes it easier to switch to any of STM32 models.

Sensor Fusion and Attitude Estimation

The IMU data undergoes sensor fusion to estimate attitude. The firmware employs complementary or Kalman filter approaches to combine accelerometer and gyroscope readings, compensating for gyroscope drift and accelerometer noise.

This fusion is critical for stable flight, providing the control loops with accurate real-time orientation data.

The STM32's floating-point unit accelerates these computations, enabling higher filter update rates than would be feasible on integer-only microcontrollers.

PID Control Implementation

The flight controller utilizes a cascaded PID scheme comprising two independent sets of control loops, one for rate control and the other for angle control. The rate control loop being of a higher frequency stabilizes angular velocity while the angle loop controls the orientation of the object.

This dual-loop approach provides responsive control while maintaining stability across varying flight conditions. The firmware supports configurable PID gains, allowing developers to tune flight characteristics for different frame sizes and motor configurations.

The STM32's timer peripherals generate precise PWM signals with high resolution, ensuring smooth motor response.

Real-Time Operating System

The firmware takes advantage of FreeRTOS, which is a real-time operating system for STM32 microcontrollers, for the management of simultaneous tasks.

The most important flight control loops operate with a very high priority level and deterministic time properties, while the less important tasks take care of the telemetry transmissions, calibrating the sensors, and processing the user inputs.

With this setup of tasks, flight-critical processes will never be delayed by less urgent processes.

Communication and Control Systems

Radio Control Interface

This platform is compatible with the common radio control protocols used for the connection of RC receivers via UART, SBUS, and PPM. The signals received by the receiver are converted into channel values and subsequently assigned to throttle, roll, pitch, yaw, and auxiliary function commands.

The modular communication structure provides flexibility in using different types of receivers with minimum efforts on changing the firmware.

Telemetry and Data Link

The telemetry system can send flight data from the drone to the ground station at varying speeds based on configuration. In-flight information such as the incline of the drone, the outcome of the engines are transmitted to the controller and can be used to track the flight.

This capability of telemetry is of utmost importance in PID tuning because it allows engineers to monitor how the closed-loop operations react to disturbances.

Development Process and Challenges

Iterative Development Methodology

This prototype was created using an iterative methodology, which means there were several phases throughout the process, such as selecting components, designing printed circuit boards, integrating the firmware, and testing the first model.

The repository format has also been adapted to accommodate this approach: separate folders contain mechanical CAD files, PCB hardware, and firmware source code. Each of the subsystem was tested in isolation so that the debugging would be easier.

Component Selection Challenges

Choosing the STM32 microcontroller entailed a conscious compromise between computing power and intricacy.

Although the STM32 comes with much more advanced processing ability than the ESP32 used in the earlier hardware platform, it is more complicated to set up with a sophisticated toolchain and does not have any built-in wireless communication.

This necessitated the inclusion of separate radio modules for control and telemetry, increasing board complexity but providing greater flexibility in communication protocol selection.

PID Tuning and Flight Testing

Achieving stable flight required extensive PID tuning, as the control gains are dependent on the specific mass distribution, motor characteristics, and frame geometry of the drone.

The process of product development involved thorough testing where the sensors were first checked for working properly, followed by trials of the motors and propellers, and then conducting controlled experiments in flight. The multilayer PID scheme made adjusting the angles and rate loops much simpler.

Power Management Considerations

The PCB incorporates multiple capacitors for power filtering and decoupling, addressing the electrical noise generated by brushless motors and ESCs.

The design of this power management is essential for the proper functioning of the STM32 and IMU since fluctuations of voltage might cause some sensor invalid readings or microcontroller resetting while performing aggressive maneuvers. The use of high-strength copper strays of PDB and protecting circuits has made the design even more reliable.

Results and Future Improvements

The prototype has proven that it can fly steadily and can be controlled electrically. The open-source principles allow for collective customization of the platform, welcoming pull requests and enhancements to its repositories.

The project roadmap outlines directions for enhancing hardware integration and improving the effectiveness of the drone. Some upgrades will include the use of custom-designed ESCs, combining Flight Controller and PDB, regulating voltage outputs, implementing automatic power reset features, improving fire safety, adding more powerful copper circuits.

Future development will also explore a lightweight 3.3V architecture, structural PDB integration, active cooling, more powerful microcontrollers such as STM32, Raspberry Pi, and ESP32 variants, along with onboard internet connectivity and telemetry for improved monitoring and control.

The items included in software roadmap are crystal oscillator accuracy testing, capacitor optimization aimed at compensating oscillators av, advanced PID algorithm based tuning, sensor calibration tools, GPS functionality innovations, and others, such as remote data monitoring, flight logging, mission planning, and telemetry support.

These upgrades will enable the prototype to evolve from being only used as a teaching tool into an advanced UAV development tool while preserving the main principles of openness and accessibility.

Conclusion

The STM32 Custom Drone Platform prototype is a demonstration of advanced microcontroller technology application in the development of UAVs.

In this way, the combination of custom-made PCBs with modular firmware enables the completion of a comprehensive, well-documented, and versatile drone platform for getting hands-on flying skills, working with PCB design, and researching UAVs.

The thorough documentation of the hardware, modular firmware, and 3D-printed frame result in reduced entry-level requirements but achieved open-source license and extensible design stimulates the innovative approaches and customization opportunities.

This prototype serves as both a functional drone platform and a comprehensive educational resource for the embedded systems and robotics communities, establishing a foundation for future autonomous flight capabilities and advanced research applications.

Project Repository: github.com/IoT-App-Development-Company/custom-drone-platform-using-stm32

What Our Clients Say About Us

Client satisfaction is our ultimate goal. Here are some kind words of our precious clients they have used to express their satisfaction with our service.

Leadership That Leads Worldwide

With a physical presence in over 15 countries and a global footprint spanning 25+ countries, we are ready to serve you anywhere. Location, language, or culture is never a barrier, because our global team can work with you in your language. Our strong international team ensures seamless collaboration across borders We have a strong tech team, highly recognized in their domains, with extensive technical expertise.