.NET MAUI Development
Xamarin Application Development
React Native App Development
iOS Application Development
Android Application Development
Android Wear App Development
Ionic Development
Universal Windows Platform (UWP)
Kotlin Application Development
Swift Application Development
Flutter Application Development
PWA Application Development
Hire Flutter Developers
Hire Certified React Native Developers
Flutter Health Tech & Wearable App Development Company
React Native Health Tech Wearable App Development
Offshore Software Development
Custom Application Development
Front-End Development
Full Stack Development
AI & Machine Learning
Custom CRM Solutions
Flask Software Development
Electron JS Development
ChatGPT Development
.NET Application Development
.NET Nuke Development
Microsoft Dynamics CRM
Microsoft Small Business Solution
VB .NET Development
C# Development
Sharepoint Migration
Sharepoint Development
ASP.NET Core Development
ASP.NET Development
ASP.NET MVC Development
Kentico CMS
Umbraco CMS
AJAX Development
Agile Development
Microsoft Bot
Microsoft Blazor
Microsoft Azure Cognitive
.Net Maui Healthcare Wearable App
Nuki Smart Lock
Salto Smart Lock
TTlock Smart Lock
NFC App Development
Smart Locker Solutions
Hospital Smart Lock Systems
Hotel Smart Lock Systems
Smart Home & Office Locks
Smart Access for Schools & Colleges
Unloc Smart Lock Integration
Yale & August Smart Lock Integration
Populife Smart Lock Integration
Smart Lock Hardware Development
RaspBerry Pi
Firmware Software Development
ESP 32 Software Development
Embedded Development
Internet of Things
IoT Sensor Integration & Development Solutions
Azure IOT Integration
Tuya IoT App Development
Particle IoT SDK
Hire IoT & Embedded Developers
STM32 Firmware & Hardware Development
IoT Development with AI
Dairy GPS Tracking Solutions
GPS Fleet Management Software
Car Rental & Subscription Solutions
Car Buy & Sell Marketplace Development
AI-Powered Car Wash App Development
PCB Design & Fabrication
IoT AC Automation
AI–IoT Painting Solutions
IoT Wearable Hardware & App Development
HVAC Automation & AI Control Systems
Smart Home IoT Engineering
AI Embedded Systems
AI Hardware Design Service
Advanced IoT Hardware & Firmware Development
Device Driver Development Services
Microchip PIC & AVR Development
Hire IoT Architects
IoT Cloud & Infrastructure Solutions
Infineon XMC / AURIX Development Services
Matter & Thread IoT Services
IoT Wearable Device Development
Native IoT Mobile App Development (BLE & Wi-Fi)
Snapdragon IoT Firmware Development
Renesas RA/RX Firmware Services
Smart Wearable App Development
Smart IoT Meters
Smart Healthcare Wearable App Development
Health Care Monitoring System
Fitness Tracking App Development
Smart Home Automation Apps
nRF PCB Design
ESP32 PCB Design
STM32 PCB Design
Embedded Wearables Engineers
Rental Property Management System
Smart Lighting Development
Infineon Semiconductor Firmware Development Services
Custom Camera Development: Hardware, Firmware & PCB Prototyping
Each type of home robot presents different challenges from a physics perspective. Indoor vacuum robots work in a strictly regulated environment characterized by flat floors, stable temperature, and good internet connectivity, as well as proximity to humans. The situation is completely different for autonomous robots operating outdoors.
Outdoor robots must work on rough slopes, under rain, bright sun, and wet grass and should be able to carry out their tasks for an extended period of time without human help. The robot should determine its location without available reference points and ensure that it does not injure a child or a pet.
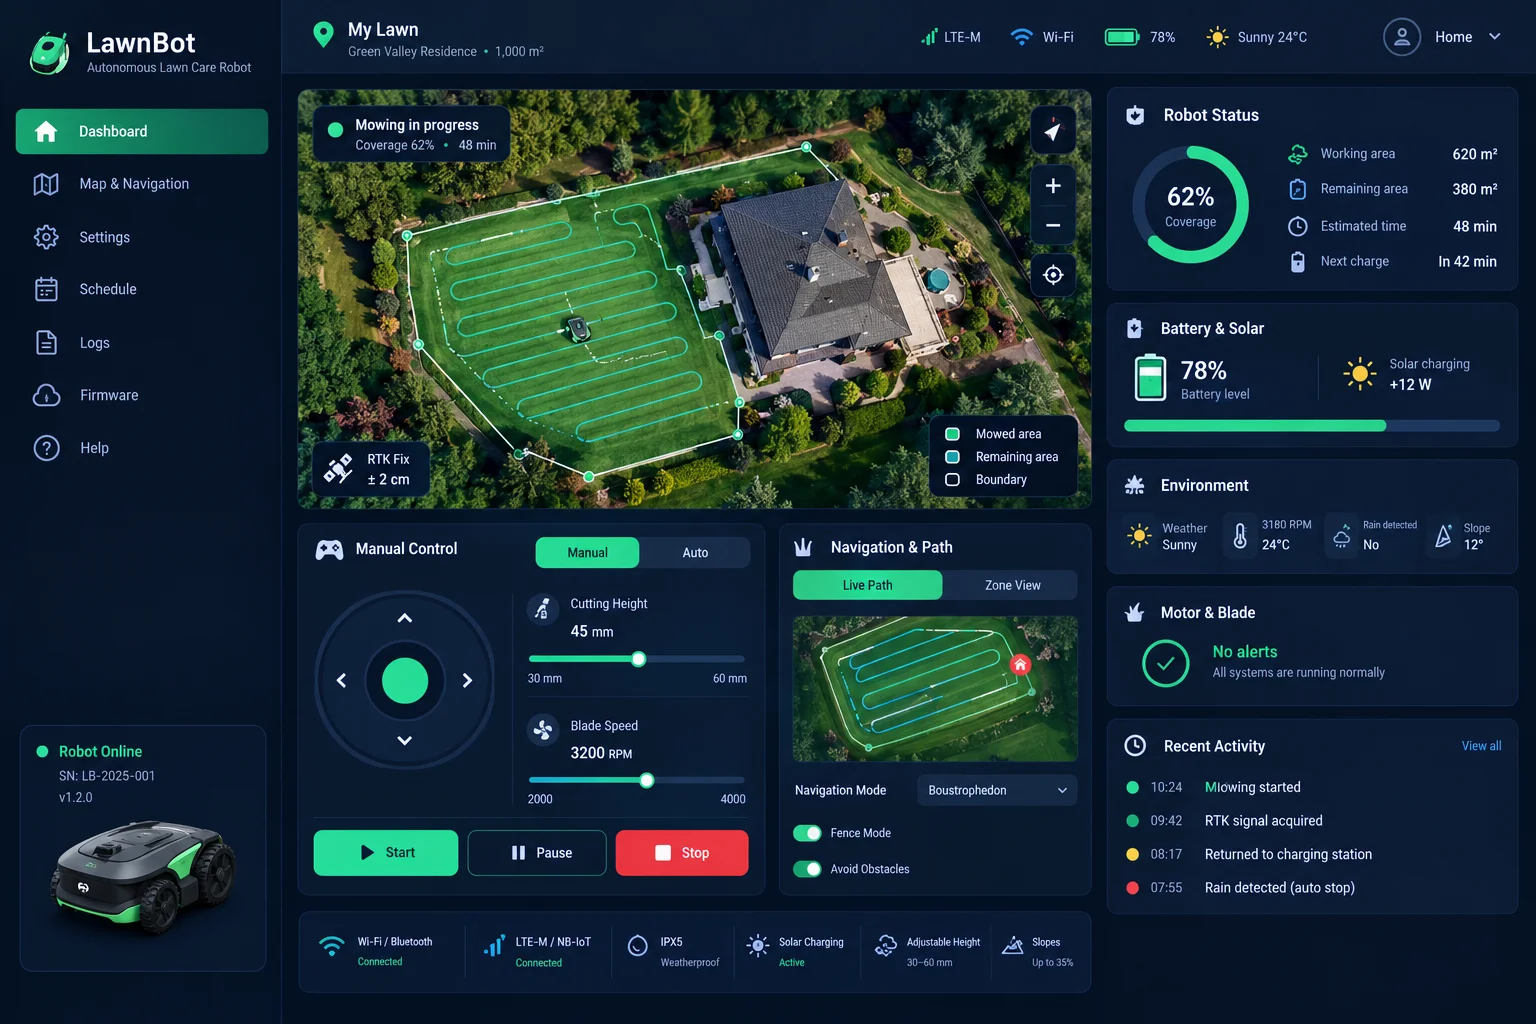
This case study describes how Adequate Infosoft designed and built the autonomous lawn care robot from the ground up, including hardware and software development.
It is a deliberately different product from the indoor cleaning robot built by the same team, and the contrast exposes exactly which engineering decisions are universal and which are dictated by environment.
The robot was specified as a wire-free autonomous mower for residential lawns up to roughly 1,000 m².
The critical word is wire-free. Conventional robotic mowers rely on a buried boundary wire carrying a signal, which the robot follows to establish its working area. Installing that wire means trenching the lawn — the single biggest friction point in the entire product category. Eliminating it was the defining requirement.
The specifications of the project also included the following requirements: adjustable cutting height (between 30 and 60 mm), ability to cope with slopes up to 35%, protection against bad weather (IPX5), device's ability to determine whether it is raining and to go back to the docking station, safety features, and LTE-M mobile communication connection with additional Wi-Fi or Bluetooth support. The battery charge should be enough for 90 minutes of work, with additional battery charge provided by solar energy.
The computing systems relied upon the same principle of layered architecture used earlier in the systems, but this time there was distinct segmentation between layer portions.
The dual-core STM32H7 microcontroller holds all deterministic tasks from motoring of knives to driving motors using field-oriented control, to taking GPS data and managing IMU fusion and reading sway and lift sensors and from there operating safety state machine.
The choice of H7 boils down to its floating point capabilities, which are important since the localization filter operates at 100Hz and FOC works at 20kHz. Both systems must meet their requirements on time without exception.
A separate ESP32-S3 module acts as the connectivity co-processor. It owns LTE-M and NB-IoT via an external modem, Wi-Fi, Bluetooth Low Energy, OTA firmware staging, and cloud telemetry.
Keeping connectivity off the safety-critical MCU means a modem hang, a TLS handshake stall, or a cellular re-registration storm can never delay a blade stop command. The two processors communicate over SPI with a watchdog on the STM32 side that resets the ESP32 if it stops responding.
This is the architectural lesson that carries across every product the team has built: never let a network stack share a processor with a control loop.
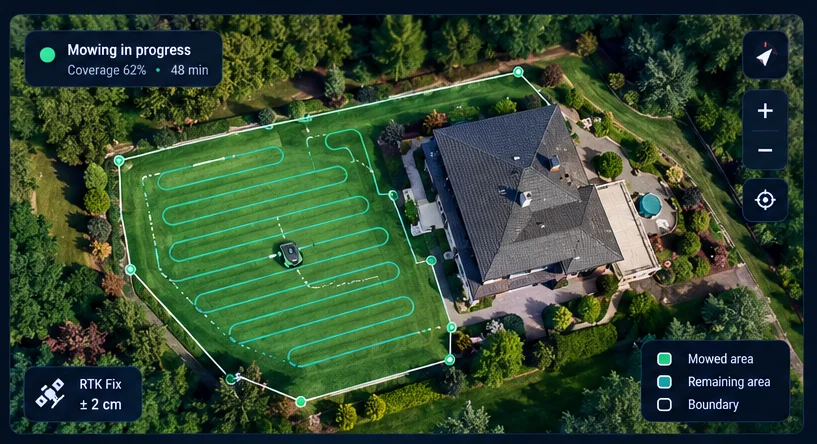
Without wires, precise positioning to the centimeter is necessary. The best technology to accomplish this task was the RTK GNSS, which made use of a multi-frequency receiver and a correction service for obtaining centimeter accuracy. The robot must create a precise map of its area, identified by the coordinates of its geofence points, and thus, the software will know how to limit the cutting path to those points.
Raw RTK is not sufficient on its own. GNSS drops out under tree canopy, against the north side of a building, and during the seconds it takes the receiver to re-converge after a fix loss.
The firmware fuses three sources in an extended Kalman filter: RTK position when the fix quality is good, wheel odometry from Hall-effect encoders on the drive motors, and yaw from a calibrated magnetometer combined with gyroscope integration.
When RTK loses its effectiveness, the filter is relying on odometry and acceleration data for a limited time; if RTK doesn't get back to normal operation in that time, then the robot ceases its working activity and travels back to open air following the previous route.
The navigation component is based on systematic boustrophedon coverage scheme with adjustable gap between sweeps and fence mode applied. The coverage is tracked as a grid of visited cells which is stored in memory.
The four-wheel chassis has an independent rear wheel drive feature and is equipped with a floating deck, which has three rotating blade assemblies.
Floating decks play an important role: on the uneven terrain, the obstacle-free fixed deck either trims the surface of the ground or leaves large areas uncut. Every blade assembly works individually, following the unevenness of the surface within a range of ±15 mm.
Brushless outrunners drive blade motors through the boards located on the circuit board. The speed of the blade is maintained by the control system and remains the same despite changes in the grass density, because a stable driving voltage would lead to difficulties in moving in thick grass.
The process of adjusting cutting height is performed with the help of a linear actuator that affects the deck mounts by means of a system of linkages, which makes the entire mechanism efficient and inexpensive. The selection of the height is done on the mobile app and kept in memory permanently, and there is also a dial to use if there is no internet connection.
Mechanical parts were modeled in Fusion 360 software. The frame parts are made of glass-nylon mixtures that offer UV resistance and impact strength, while the housing and deck are manufactured using ASA material that can withstand UV degradation much better than PLA or PETG during several seasons of being used outside.
The battery consists of a lithium-ion pack with six cells and a nominal voltage of 22.2 V and a capacity of about 5 Ah. A BMS is built into the design of the battery to handle cell balancing, to prevent over-discharging, and control charging based on temperature.
The charging of the battery is accomplished using gold-plated spring contacts at the dock. Additionally, the robot has a 20 W solar panel mounted on top of the machine.
The solar panel cannot charge the battery directly due to the suboptimal parameters of voltage and current. The aim of the panel is to keep up the battery cells charged and make sure that the robot systems receive power.
This is a subtle but important design choice. It means the robot can sit undocked for weeks in standby, remaining reachable over cellular, without draining the traction pack. Field data showed this reduced idle drain from roughly 4% per day to under 1% per day.
The process of thermal design was not easy. The motors of the deck and the drivers of the FOC release the heat in a closed-in housing where the sun is directly coming into. The PCB makes use of copper pours that are dense under the driver stages and in addition, the style has a passive vent path that achieves IPX5 together with convection of air.
Safety architecture is required that does not depend on the intention of the software.
Both lift and tilt detection employs two separate systems for measuring tilt. The first system uses an IMU to calculate the maximum allowed tilt angles as part of the STM32 control loop, while the second system consists of the hall-effect sensor located on the deck mounting which will open as soon as the chassis of the deck is lifted.
As soon as any of these two systems detect the condition, they will turn off power to the blades in less than 200 ms using a hardware gate. This is done using a separate circuit, and not a GPIO write, so that even if there is a firmware hang, the possibility of the blades continuing to rotate is ruled out.
Additional protections include bump sensors on the front bumper, ultrasonic sensors for obstacle detection at mowing height, rain detection that triggers a return-to-dock, and a geofence violation handler that halts the robot immediately.
The safety state machine is implemented as an explicit transition table with no implicit fallthrough, reviewed line by line as a standalone artefact.
The LTE-M was selected instead of NB-IoT due to its shorter latency along with support for firmware downloading of large sizes.
ESP32-S3 maintains a constant TLS connection with the cloud, and sends telemetry data after every minute, including position, battery condition, number of hours of cut, motor temperature, error codes along with how the search is proceeding. Command is sent from the cloud down to the machinery, such as to start cutting, stop operating, return home, create a schedule to follow, set the cutting height, etc.
Cloud backend provides OTA updates with A/B partition rollback capability for devices that fail to boot from OTA. If a device does not boot up after an OTA update, it automatically reverts back to the state before the OTA update; it is extremely helpful when the device is in a garden and cannot be retrieved physically.
The Android and iOS apps provide means to provision and define geofences on satellite maps, set schedules and manually drive the device.
Geofence definition is the highest-risk interaction in the product: a malformed polygon means the robot escapes the lawn. The app validates the polygon for self-intersection, minimum area, and slope feasibility before uploading, and the robot re-validates on receipt.
The validation process was completed in stages. The bench testing assessed FOC loops, encoder linearity, and RTK-odometry-inertial filter according to saved data.
Scheduling in the setup helped in implementing the hardware-in-the-loop experiment. It included injecting simulated GPS failure in order to stimulate the state machine.
Field tests were conducted in three different seasons as well as using various adversarial cases, such as mowing the lawn at the geofence edges at the angle of 30 degrees, restoring the functioning of the RTK system in the presence of a tree cover as well as during the winter storage period.
Manufacturing readiness included DFM-reviewed PCB layouts, Gerber and pick-and-place files, a complete bill of materials, assembly drawings, and test fixtures for production validation of motor drivers and RF performance.
The main issue was not localization or the control of the motors, as those were manageable, the real issue was the interaction of these two elements. The combination of RTK loss on a slope and the slip of the wheels turning on an incline caused odometry errors which could not be contained by the filter.
The proposed solution was slip detection. By comparing the speed derived from encoders with the speed calculated by the IMU and increasing odometry uncertainty when the two measurements differ, all failures where the robot lost track of its position and started mowing the lawn of their neighbor.
The second lesson we had to learn was that solar energy is not a source of power in this case but a backup power method. This approach made it possible to turn a minor detail into a crucial element.
The system provides unrestricted autonomous mowing with accuracy of several centimeters, cellular communication, full battery charge through solar energy, as well as safety measures appropriate for the use of unshielded blades.
The development plan includes a system for the analysis of obstacles allowing distinguishing between leaves and animals, zonal management of several lawns with automatic transit between the zones, swarm cooperation on large areas, and robotic trimming of edges.
Outdoor robotics is a true test of design for the extreme and not the average. Unpredictable weather, terrain, RF blackout, heat, and long periods without maintenance are not nevertheless exceptional conditions - they represent the actual range of operation.
The outdoor robot made use of various levels of electronics design, including real-time mash-up MCU without network stack, a progressive fusion filter, a separate safety mechanism, and the strategy for operation at solar power with no contact with the main battery and motor.
Developed from the simplest mechanical parts and the simplest boards to the cloud applications, the project shows by practical means the scalability of the methodology applied.
Client satisfaction is our ultimate goal. Here are some kind words of our precious clients they have used to express their satisfaction with our service.
I came across Adequate Infosoft while searching for an IT company to design a virtual platform for my Telemedicine business. AI helped me to make my dream project a reality.
Frederick Hess
The price and professionalism of Adequate Infosoft's project team are the most appealing aspects of working with them. The team provides weekly progress reports and responds quickly to the concerns I have.
Kim Jespersen
My team is very satisfied with the professionalism shown by the Adequate Infosoft team during the project. We are looking forward to working with them again.
Óli Freysson
I contacted AI for an Android and iOS application and I am completely satisfied with their service.
Thomas Cheah
I am very satisfied with Adequate Infosoft. very helpful, positive, and quick communication so far. I am looking forward to further cooperation.
Great experience hiring them, understood the requirements very well, and were very effective and efficient in delivering the project. I will hire them for my next project as well and also recommend them to others.
Adequate Infosoft lead development team is efficient and provides the best IT solutions. If you're looking for quick and affordable software development, Adequate Infosoft is your go-to guru!
Adequate Infosoft has stood out to be the best company for providing IT services at affordable prices. Their rapid development approach works in line with our iterative process.
David Kattah
We have worked with Adequate Infosoft for 4 years and it has been a positive experience for me and my company.
Frank Eson
Adequate Infosoft has set a benchmark with its robust product development services. Their development team is highly professional that understands the value of time.
Exceptional service! The AI team guided me through the entire procedure and made it an enjoyable experience.
Kim Jespersen
As a small business, we were most attracted to Adequate Infosoft's competitive pricing and the ability to quickly scale up or down the number of developers supporting the application.
Mr. Aaron
It was a pleasure to collaborate with Adequate Infosoft. Their development team is comprised of true experts.
Adequate Infosoft helped us get the most from Ceraphi, with smooth setup, responsive support, and practical, effective solutions.
Adequate Infosoft helped us develop our smart lock solution, including both the mobile app and web app
The Adequate Infosoft team helped us deliver a custom IoT solution for our European customers very efficiently
Smart Controls
Adequate Infosoft did a great job, helping us implement energy-efficient solutions smoothly.
Australia Health Pty Ltd
The team understood our needs and delivered quality health tech solutions on time.
Adequate Infosoft felt like a true partner, very supportive team, clear communication, on-time delivery, and quality work we genuinely trust.
With a physical presence in over 15 countries and a global footprint spanning 25+ countries, we are ready to serve you anywhere. Location, language, or culture is never a barrier, because our global team can work with you in your language. Our strong international team ensures seamless collaboration across borders We have a strong tech team, highly recognized in their domains, with extensive technical expertise.
Architect & Solution-Level Expert | Recognized Thought Leader with 8k+ LinkedIn Followers
Certified Developer | Driving AI, ML & Data Science Solutions
17+ Years in AI & IoT | 7,000+ Followers | Recognized Technology Leader
20+ Years in Tech | AI & Cloud Architect | HealthTech Innovator | 3,000+ Followers
IoT4All | IoT & Hardware Expert | Established Reputation in Europe
Technology Director at AOTC Limited, certified in CISSP, TOGAF, and SAFe. Leading technical operations across UK, Australia & New Zealand. Former Principal Integration Architect at Vodafone. Available on WhatsApp: +44 7563 407814, +61 458 765 85.
Helping SMEs Overcome Digitalization Challenges | Startup Tech Expert
AI, Life Sciences, HealthTech & Robotics Expert | 8,000+ Followers
25+ Years in Tech | Cloud Consultant | Lead Developer
SFMC Consultant & Developer
Cloud & AI Consultant
Tech Consultant • Sr. Application Developer • IoT & Hardware Expert
AI, IoT & Cloud Expert | Software Consultant
SAP Developer • Technical Consultant | ERP Solutions Specialist
Database & Network Expert • Mobile & Web Architect
Java Developer | Backend & Application Specialist
Engineer & Technology Consultant
Developer • Technical Consultant | Solutions & Strategy Expert
Technical Consultant | IT Strategy & Solutions Specialist
Technical Consultant & Developer
Cloud Solutions Expert with 17+ Years of Experience | HBIT Graduate | AI, IoT & Scalable Architecture Specialist
Lead Architect, Java Developer specializing in RESTful Services & Mobile Applications
Technical Consulting & Speaking | ANZ Region
Product Leadership & AI Architecture
Product Engineer (Python, C#, JavaScript, SQL) | Software Engineer & Speaker
Specializing in servers, virtualization, and network infrastructure
IoT Leadership | Global Operations | Digital Transformation
PMP-Certified Expert in IoT, AMI & Smart Metering
Send your message in the form below and we will get back to you as early as possible.
Your request has been sent successfully!